Welcome to our community

Be a part of something great, join today!

  • Hey all, just changed over the backend after 15 years I figured time to give it a bit of an update, its probably gonna be a bit weird for most of you and i am sure there is a few bugs to work out but it should kinda work the same as before... hopefully :)

DJI RONIN PRO SUPPORT

Regarding the Pan wobbling, I have just sent an email to Ronin support and will report back. I'll also try to post a video when I get a chance. In the meantime I will appreciate very much if Peter and maybe others get a chance to try and replicate the issue. I will do so with the demo unit of my dealer today.
 
Hi Christoffer,

I was gonna say you could ask grips to carry a pop up tent for you if an umbrella gets in the way =)
But if for whatever reason you would want to take the Ronin into heavy rain without an umbrella or tent (which I always prefer, as they keep me dry, too) why not try putting some sort of very thin pastic bag or film over it? Attach it to the handles, and if the ronin accepts it to be attached to the lens - perfect. If it is disturbed by it, or just for greater flexibility, you could try building a support structure with very thin carbon rods and attach it to the handles so that the gimbal moves freely. Both options will limit your range of movement a bit though I guess.


It would be nice if DJI made a custom made rain cover for the Ronin, instead of trying to handle it with plastic bags. My experience is that it's rather hard to find proper rain covers, even for a regular camera setup.
There should be something better that take into account the fans and heating of the camera. And for the gimbal, something that makes it just as stable as without.
 
Hi do I order the ronin?

There is no ordering option in the official page?
 
Only able to purchase through dealer and not from DJI directly? Is the price standardized across the dealers?
 
Pan Axis issue

Pan Axis issue

Ok, here's an update on the pan axis issue.

I just came back from thundertiger, the short answer is, their demo unit exhibits the same issue, but worse actually.

Findings
Their unit has the same problem that I described earlier, that if you rock the handle bars in the roll axis, the pan axis will overload and shutoff, resulting in pan wobbling, and if continued, a safety shutoff of all motors for a few seconds. On theirs actually it doesn't even take fast movements, normal speed movement of the handles in the roll axis is enough to trigger a shutoff if the angle is steep enough, and any fast movement regardless of the angle will trigger a shutoff as well. With that degree of the issue, I'd say it's barely useable.

We made a video and sent it to DJI, I'll keep ypu posted on their response.

Possible cause (My personal guess, and pure speculation right now)
Now what I did notice when balancing their Ronin is, that the balancing issues I described earlier are more pronounced as well. With Roll and tilt properly balanced on the stand in underslung mode, and the Ronin then turned it into briefcase orientation to balance the pan axis, properly balancing the pan axis prooves impossible, indicating its de-centered. After dialling it what seems to be proper balance, it will always return to a horizontal orientation - turn the arm one way it comes back indicating front heavyness, turn it the other way and it comes back indicating it'd be back heavy -> this (to me) is proof that the pan axis is not perfectly centered in the pan arm, and off to one side.
Anyone who has turned a non-dynamically balanced steadicam knows that an axis that is ever so slightly off-center axis can cause huge forces when rotated.
Now, if the Pan axis is decentered, moving the gimbal in the roll axis will mean that the pan motor needs force to keep the pan axis straight as there will be a weight shift when the handles are moved, which it wouldn't need at all if it was properly centered and balanced (see the Ronin manual that asks you to lift a handle and check for no movement to ensure proper pan balancing).
My copy of the Ronin exhibits the balancing issue to a lesser degree, and needs more rocking to reach the high power levels to shut off. The demo unit shows the balancing issue more, and requires even less movement to trigger a high power shutoff.
To me this is all consistent with my assumption, that on some units, to varying degrees, the pan axis and / or other axes are decentered - leading to forces being generated that are too large for the motors to compensate.
As I said, at this point this is my conclusion from looking at 2 units, and expressly my personal speculation.


Unrelated to this issue, we also noted that the downward tilt axis hard stop on their system is about 10° different than on mine. Not that this would be a problem (at least it doesn't seem like it for now), as it is way past the maximum endstops anyway, but it shows there is significant product-to-product variance.


As I know how onliune posts are interpreted sometimes, please note that this should in no way convey a negative tone towards the Ronin - I am absolutely impressed by the unit and like it a lot so far - all I intend to do is actively help improving on this issue and keep you guys in the loop.
 
Only able to purchase through dealer and not from DJI directly? Is the price standardized across the dealers?

Mike, yes - DJI does not sell directly - you have to purchase via a local / nearest dealer. This is a business model adopted by many companies in our industry with global reach.
The price is standardised for all dealers - but do note that the price can be affected by local import taxes and fees. Also shipping charges may vary depending on your location and distance from the dealer.
Hope this helps...

:sifone: Peter
 
It would be nice if DJI made a custom made rain cover for the Ronin, instead of trying to handle it with plastic bags. My experience is that it's rather hard to find proper rain covers, even for a regular camera setup.
There should be something better that take into account the fans and heating of the camera. And for the gimbal, something that makes it just as stable as without.

Chris - this might be the case of choosing the right tool for the job. As you have stated - Steadicam can be easily adopted for shooting in rain.
The nature of gimbal operation and the requirements of unobstructed free movement would make this extremely difficult to make a rain cover for a gimbal.
This is an equivalent of asking Apple to make a rain cover for the laptops - which ironically is much easier then making one for a gimbal.
Having said that - there are various solutions for when we mount gimbals to helicopters and other fast moving platforms - where the main reason for the protection is to isolate the gimbal from the brutal wind forces. It is rare to use these in a rain...:

C516-LCU-for-Web1-1024x521.jpg


http://gyrostabilizedsystems.com/products/c516

But these systems are too cumbersome and almost exclusively for remote operation mounted to various moving platforms.
You could experiment by sealing off the battery and key electronics at the back of the Ronin and then sealing the camera together with the base break-out power box - but do so at your own risk...

:sifone: Peter
 
Hey Guys! So our Ronin arrived a few day ago and the first test went really well.

The only thing i`m really concerned about is the power solution. Currently we`re powering the epic of the sidehandle as many others but that wont work for a real 8+ hour day.

I want to get as much weight away from the gimbal itself as i need to work with the Ronin with Mattebox, Element Technica FF, Paralinx, and Lenses like Schneider Xenon, Cooke S4 or maybe even something heavier.

I`m thinking about building a custom cable like this: http://www.brushlessgimbals.com/p/8723946/superthin-90-power-connector-for-red-epic.html
It should run from the camera into the hole from the D-Tap Powerbox(under the camerplatform) through the gimbal and then into a vmount plate that i can carry on my back.

Has anyone experience with something like this?
 
Ok, here's an update on the pan axis issue.

I just came back from thundertiger, the short answer is, their demo unit exhibits the same issue, but worse actually.

Findings
Their unit has the same problem that I described earlier, that if you rock the handle bars in the roll axis, the pan axis will overload and shutoff, resulting in pan wobbling, and if continued, a safety shutoff of all motors for a few seconds. On theirs actually it doesn't even take fast movements, normal speed movement of the handles in the roll axis is enough to trigger a shutoff if the angle is steep enough, and any fast movement regardless of the angle will trigger a shutoff as well. With that degree of the issue, I'd say it's barely useable.

We made a video and sent it to DJI, I'll keep ypu posted on their response.

Possible cause (My personal guess, and pure speculation right now)
Now what I did notice when balancing their Ronin is, that the balancing issues I described earlier are more pronounced as well. With Roll and tilt properly balanced on the stand in underslung mode, and the Ronin then turned it into briefcase orientation to balance the pan axis, properly balancing the pan axis prooves impossible, indicating its de-centered. After dialling it what seems to be proper balance, it will always return to a horizontal orientation - turn the arm one way it comes back indicating front heavyness, turn it the other way and it comes back indicating it'd be back heavy -> this (to me) is proof that the pan axis is not perfectly centered in the pan arm, and off to one side.
Anyone who has turned a non-dynamically balanced steadicam knows that an axis that is ever so slightly off-center axis can cause huge forces when rotated.
Now, if the Pan axis is decentered, moving the gimbal in the roll axis will mean that the pan motor needs force to keep the pan axis straight as there will be a weight shift when the handles are moved, which it wouldn't need at all if it was properly centered and balanced (see the Ronin manual that asks you to lift a handle and check for no movement to ensure proper pan balancing).
My copy of the Ronin exhibits the balancing issue to a lesser degree, and needs more rocking to reach the high power levels to shut off. The demo unit shows the balancing issue more, and requires even less movement to trigger a high power shutoff.
To me this is all consistent with my assumption, that on some units, to varying degrees, the pan axis and / or other axes are decentered - leading to forces being generated that are too large for the motors to compensate.
As I said, at this point this is my conclusion from looking at 2 units, and expressly my personal speculation.


Unrelated to this issue, we also noted that the downward tilt axis hard stop on their system is about 10° different than on mine. Not that this would be a problem (at least it doesn't seem like it for now), as it is way past the maximum endstops anyway, but it shows there is significant product-to-product variance.


As I know how onliune posts are interpreted sometimes, please note that this should in no way convey a negative tone towards the Ronin - I am absolutely impressed by the unit and like it a lot so far - all I intend to do is actively help improving on this issue and keep you guys in the loop.

Frederick - I tried this on my unit and was unable to duplicate this issue. Could you please forward me the video so I can see what is going on? Please send the link to peter(at)derylgroup(dot)com

:sifone: Peter
 
Hey Guys! So our Ronin arrived a few day ago and the first test went really well.

The only thing i`m really concerned about is the power solution. Currently we`re powering the epic of the sidehandle as many others but that wont work for a real 8+ hour day.

I want to get as much weight away from the gimbal itself as i need to work with the Ronin with Mattebox, Element Technica FF, Paralinx, and Lenses like Schneider Xenon, Cooke S4 or maybe even something heavier.

I`m thinking about building a custom cable like this: http://www.brushlessgimbals.com/p/8723946/superthin-90-power-connector-for-red-epic.html
It should run from the camera into the hole from the D-Tap Powerbox(under the camerplatform) through the gimbal and then into a vmount plate that i can carry on my back.

Has anyone experience with something like this?

Hi Kaspar! I doubt that this would work. The cable would need to be rather thick to sustain the current draw required by the RED and you will find it difficult or even impossible to route this cable throughout the Ronin without impacting its ability to move freely and unaffected.
The FREEFLY's side-mounted compact V-lock when combined with the IDX Endura E-7s battery is not that much heavier then the RED SIDE HNDLE + REDVOLT combo - and it gives you double the run time and easy swap capability for the batteries.
FREEFLY has the longest experience in making gimbals for RED cameras and there is a reason why they have chosen this direction to power up the RED.

At the end of the day you are looking at negligent difference in the total weight when compared to the SIDE HANDLE + REDVOLT combo. Unless you have a strong operator and plan your shoot accordingly - you will need some sort of support system - like the EasyRig + Serene combo...

:sifone: Peter
 
Thanks for the fast reply Peter!

But how the hack do all the copter guys power their epic with super thin cables and lipos? Isnt it the same Problem?

And a supporting system is a real must have for long days... I`ve seen some Photos with a Gimbal on a Steadicam arm. As i already have an Actioncam Raptor, mounting the Ronin directly on the arm would make the most sense. Have the Ronin mounted on the Sled should be the smoothest option, but i think it would be really painful to balance and you would not be able to use all three axis of the gimbal?! But lets give it a try if i find time to build an Adaptor... :lol:

Kaspar
 
Last edited:
But how the hack do all the copter guys power their epic with super thin cables and lipos? Isnt it the same Problem?

Most of the time they just velcro the LiPo's directly to the camera. You gotta watch out for how the LEMO sticks out from the camera - in the link you have shared it sticks out to the side in a way that could potentially hit the side arms if you need to balance the camera. I would much prefer it sticking to the other side blocking ports that are not used anyway. Or just slightly lower bellow them. Why can't LEMO make a proper rotating 90˚ connector? ;o)
I have also seen folks to just run these thin cable freely to either the handle bar, or a belt-clip - but this will impact on the final results. The motors on the Ronin are strong enough to cope with some of these thin cable forces, but that does not mean they should be used like that. Folks should do so at their own risk...


I`ve seen some Photos with a Gimbal on a Steadicam arm. As i already have an Actioncam Raptor, mounting the Ronin directly on the arm would make the most sense. Have the Ronin mounted on the Sled should be the smoothest option, but i think it would be really painful to balance and you would not be able to use all three axis of the gimbal?! But lets give it a try if i find time to build an Adaptor...

Steadicam solutions do make a lot of sense. You will not have a problem balancing it on a sled - providing you have balanced it beforehand on its own in the first place. It should also not restrict the gimbal's motion.
When you work on your bracket - keep in mind that mounting it to the Steadi would almost always require the upside-down orientation. In which case you should just mount the camera upside-down in the Ronin to begin with, so it is right way up on the Steadi.

Keep us posted on this!

:sifone: Peter
 
Makes a lot of sense Peter. Thanks!

But maybe i will give the cable through the Ronin a try even if it is just to prove your point ;)
Otherwise the FREEFLY V-Mount should work perfect.

I`m more than happy with the kina results with the dragon + steadicam but it think adding the Ronin would open a completely new door... Let see what is possible.

Sure i'll keep you updated!

Kaspar
 
Hi all,

I will have the guys from thundertiger forward me the video and post it here tomorrow.

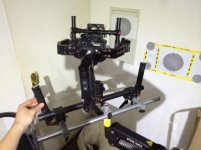
In the meantime, Kaspar, attached is an image of a prototype (or better: a quickly thrown together just to test while waiting for a proper bracket) mount directly to a steadicam arm.
It works well, of course only with the remote, or better the thumb control I can't wait to see and get - although I have to say already after the first tests that I will prefer an option like the serene arm
as any angular changes from the steadicam arm post transfer into ever so slight position changes since the actual gimbal is much further away from that point than on a steadicam, resulting in
rather delicate handling compared to a steadicam sled.
 

Attachments

  • photo.jpg
    photo.jpg
    34 KB · Views: 0
So I would love some clarity on using the Redrock Remote FF system with the Ronin. I've now heard from a second person here on the forums that their system is flashing rapidly indicating a "low battery" status when running from the p-tap. Official redrock tech support says it needs 12.4v to run and official DJI tech support says Ronin is 12.8v. I wouldn't mind it flashing except mine keeps power cycling after a few minutes of use. This is very frusterating as I was told it should work from both companies.

Can DJI test this out and see if there's a way to force and extra .2 volts out or some other adjust I can make on my end?

Voltage is certainly not an issue - if anything it would be the current. The RRM should only draw 2 amps and the Ronin supports 3 amps combined between the two P-tap ports. A siezed motor or lens barrel could easily draw more then the specs state. Try powering it from another source while on the gimbal but with the motors killed. See if the motor and lens work smoothly and without any issues.
I have been using the Ronin with several brands of FF (but I don't have the RRM) and never had any issues. And lot of these motors are more powerful then the RRM one...

Also - are you running any other accessories from the break-out box?

:sifone: Peter
 
I have successfully made the system work with a Paralinx Arrow+ and a Bartech BDR, both powered from the power box bellow the camera receiver. I know it doesn't help those with issues with the RR, but it shows that the system works with other types of equipment.
 
I have successfully made the system work with a Paralinx Arrow+ and a Bartech BDR, both powered from the power box bellow the camera receiver. I know it doesn't help those with issues with the RR, but it shows that the system works with other types of equipment.

Ditto here - works while powering Paralinx + C-Motion or ARRI follow-focus. Not sure what the issue is with the RRM.
I need to hear from anyone having issues with the RRM what other accessories are they powering from the break-out box...

:sifone: Peter
 
Back
Top