Welcome to our community

Be a part of something great, join today!

  • Hey all, just changed over the backend after 15 years I figured time to give it a bit of an update, its probably gonna be a bit weird for most of you and i am sure there is a few bugs to work out but it should kinda work the same as before... hopefully :)

TRIBAL SNAKE

Antony Newman

Well-known member
Joined
Mar 7, 2012
Messages
1,805
Reaction score
6
Points
38
Location
London, UK.
TRIBAL SNAKE

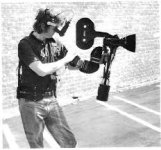
Note: This is not yet a living breathing product; It is my third attempt to create the best possible design for a mobile Gimbal.

The Snake represents what I believe is the endpoint for Gimbal structural design.


AJ%252520Tribal%252520Snake.png


AJ

Spherical Gimbal : http://www.reduser.net/forum/showthread.php?131576-SPHERICAL-GIMBAL
Tribal Spirit : http://www.reduser.net/forum/showthread.php?131915-TRIBAL-(TRIpod-meets-gimBAL)
 
Last edited:
TRIBAL SNAKE - What problems are SOLVED in this concept?

+) CENTRE OF GRAVITY : The Snake balances out the weight of the camera in front of you, through articulating its tail.
RESULT = You don't tip forward. Natural position for your spine.

+)
HANDS FREE : Fully articulated. Fully active. All weight transferred to your hips.
RESULT = Your arms can relax when standing still. Arms can be used when you are RUNNING for balance.

+) HANDS ON : When required. Hold and move Snake Head directly. Weight of entire system still transmitted to hips.
RESULT = Snake can make head 'weightless', or introduce drag or damping to user preference.

+) GESTURE CONTROL : Fly by wire. User 'charms the Snake with Hand/arm/user head/user eye Gestures
RESULT = Effective panning shots from the Ground to above head height.

+)
STABILIZATION : When jumping up and down, the FULLY ARTICULATED snake can completely isolate the camera.RESULT = No Bobbing up and down ... even when RUNNING

+) TURNING CAMERA : Snake can use TAIL to actively assist moving the camera head.
RESULT = Camera Lens can turn easily around OPTICAL CENTRE

+) POWER : Either distributed around Hips as part of 'Power Belt'. 'Puffer battery' in articulated Tail sections.
RESULT = Plenty of power. Power modules on belt easily swapped out.

+) CAMERA CONTROL : Extension of RED SDK (one API). RED GUI displayed in MS HoloLens Visor as a remote surface.
RESULT = Point and Click in RED Weapon GUI = Eye tracking in Visor. No need to learn a new GUI. Super easy to write an App.

+) RUNNING : The Tail and Head can articulate like a Cheetah's tail
RESULT = Sudden change of direction now possible - with tail absorbing inertia.

AJ
 
Last edited:
Technology Corner : Articulation Research #1

Dr Michael M Porter's research shows lightweight systems based on nature that are able to articulate in segments.

Dr%252520Michael%252520M%252520Porter%2525201.png


Dr%252520Michael%252520M%252520Porter%2525202.png


What Michael determined through simulations was that the box section of the Sea Dragon created a far stronger (ie less deformable) structure compared to other of nature round cross sectional area creatures.


(I will present my own thoughts on active articulations in due course.)

AJ
 
Last edited:
Tesla's research :

Robot with Articulated sections


Thoughts : This uses 'hard' robot parts that are heavy - but is conceptually similar to the 'soft' robot that I believe is needed for the ultimate gimbal.

AJ
 
Visor - Control system

So ... one piece of the control puzzle is Finnnallly going to be released by Microsoft - sometime (probably Q3?) 2016.

http://techxplore.com/news/2015-12-hololens.html

1-hololensdeve.jpg


I think this is the 'right way' to see what a RED can see - And currently envision this to be a Virtual Display that appears on a screen that stays in the same 3D space when you move your head.

If EYE tracking works - the controller should be able to Look at the Virtual screen ... and when (or if!) technology exists ... with a bit of coding magic ... we might be able to work out the focal distance from the Camera to the object .. and send a Command by Redlink Command Protocol to focus the the new distance.

Around the virtual screen there will need to be the minimum of controls and or instruments to give the filmmaker what they want to see.

Question : What instrumentation would you like included?

AJ
 
Depth Sensing Technologies

Toposens is one of the companies working on RADAR / ULTRASOUND for 3d mapping purposes.

They are working on items for the tail end of 2016

https://vimeo.com/138140480

https://vimeo.com/138728150

The above item is very small and light.

They are working more less flat out on 'larger use cases' of their products first which will keep them busy at least until the end of 2016.

My hope is that depth information from an on-camera device could be Mapped ontop of a 2D display of what the camera sees.
When the camera operator looks and a point on this 2D display and gestures a 'FOCUS' - that this information could be sent to the camera to refocus (or maybe even to Track)

AJ
 
Last edited:
Articulated joints may require floating stiff joints with a soft-robot actuation or encapsulation.

Carbon Fibre is strong but not particularly hard (and therefore not particularly hard wearing / durable)

Could this material become a happy compromise for light weight moving parts that require direct transfer of loads?

Magnesium Infused with (ceramic) Silicon Carbide

http://www.sciencetimes.com/articles/8016/20151224/strong-light-supermetal-created-labs-ucla.htm

http://phys.org/news/2015-12-exceptionally-strong-lightweight-metal.html

AJ
 
Back
Top